M.Sc. thesis · McGill University, NeuRoc Lab · 2025–present
Physical human–robot co-manipulation
How a cobot can share a load with a person who has tremor.
The problem
People with tremor struggle to hold and move objects steadily. A collaborative robot can carry part of the load, but it must follow where the person wants to go and damp the tremor at the same time, and those goals pull against each other.
What I did
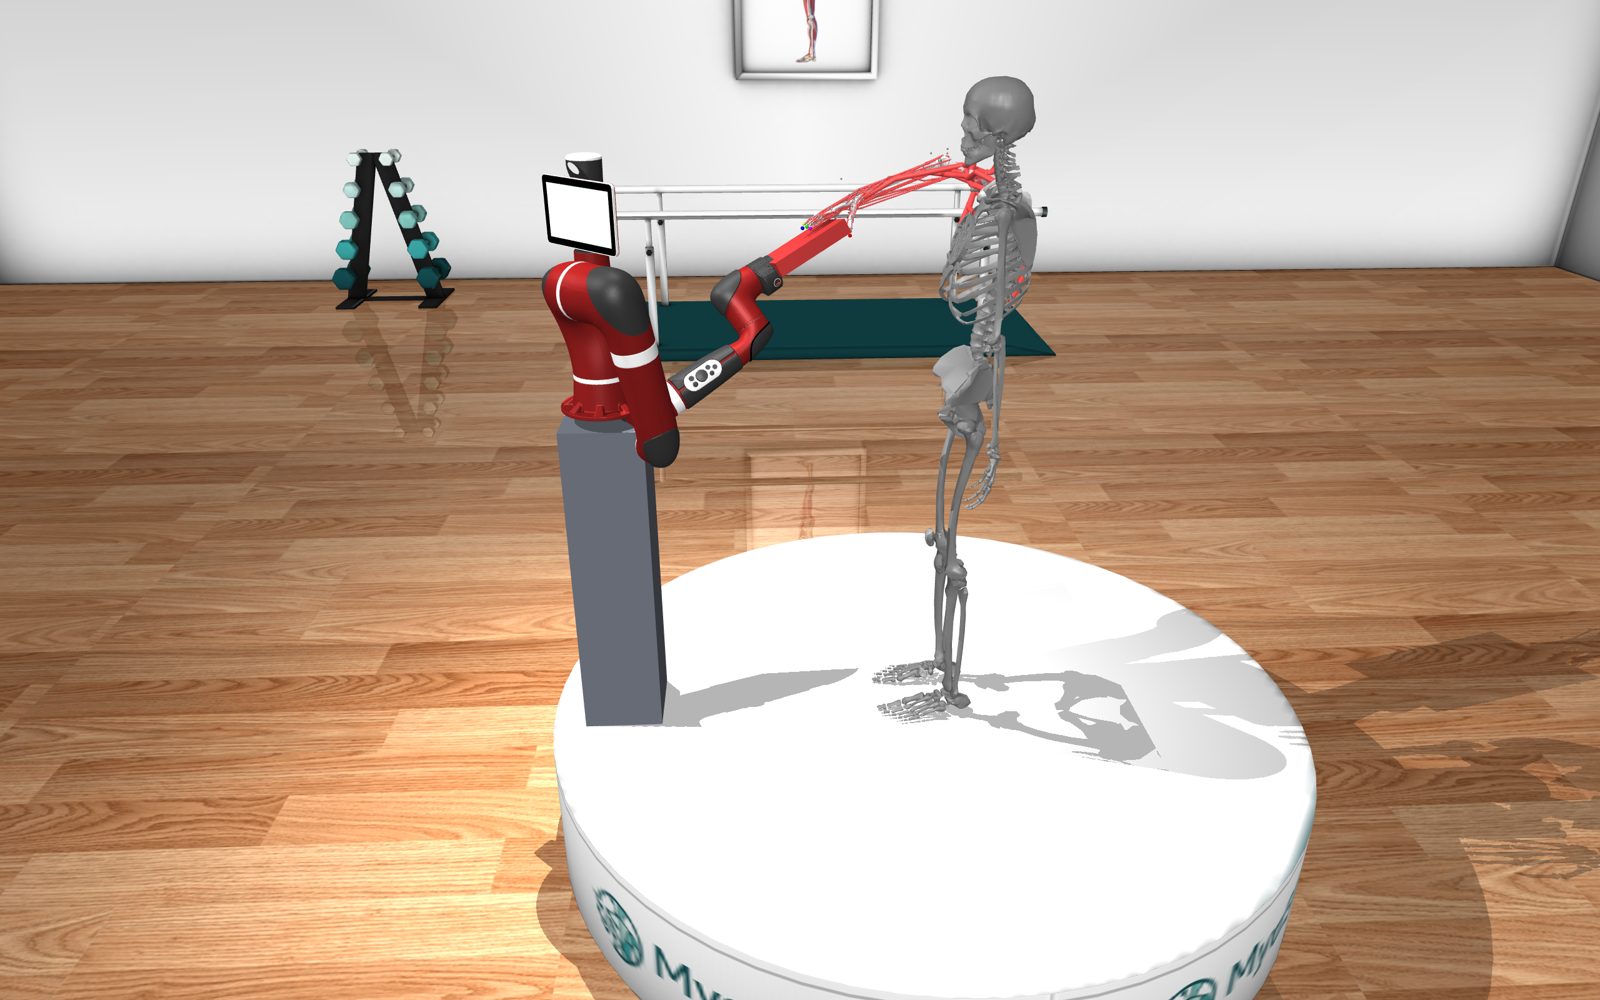
- A Sawyer cobot under Cartesian admittance–impedance control
- Physically coupled in MuJoCo to a MyoSuite musculoskeletal arm model
- Tuned the controller and swept its gains across loads and tremor conditions
- Mapped the trade-off between load support, intent following and tremor attenuation
Results
With the right settings, the robot lets the simulated person carry loads they cannot hold alone and clearly reduces the tremor it can act on, while still following their motion. The results are being prepared for publication and the work is moving to a physical robot.