I work on motion control, Model Predictive Control and ROS 2 navigation, currently for a smart autonomous wheelchair. I am finishing an M.Sc. in Mechanical Engineering at McGill, with research in physical human–robot co-manipulation.
Control engineer, finishing an M.Sc. at McGill.
I like control problems where the model is never quite right: a wheelchair carrying a passenger whose weight changes, a quadruped picking up a payload, a cobot sharing a load with a person whose hand trembles. My work is building models good enough to control with, and controllers robust enough to cope with what the models miss.
Today I work remotely as a Robotics and Control Engineer at a robotics startup, on navigation and motion control for a smart wheelchair. Before that I built a medical device prototype from circuit to app. I want to bring this mix of control theory and hands-on engineering to a robotics team, wherever control and dynamics matter.
Control and robotics work across industry and research.
Navigation and motion control for an electric wheelchair at a robotics startup, built on ROS 2 and Nav2.
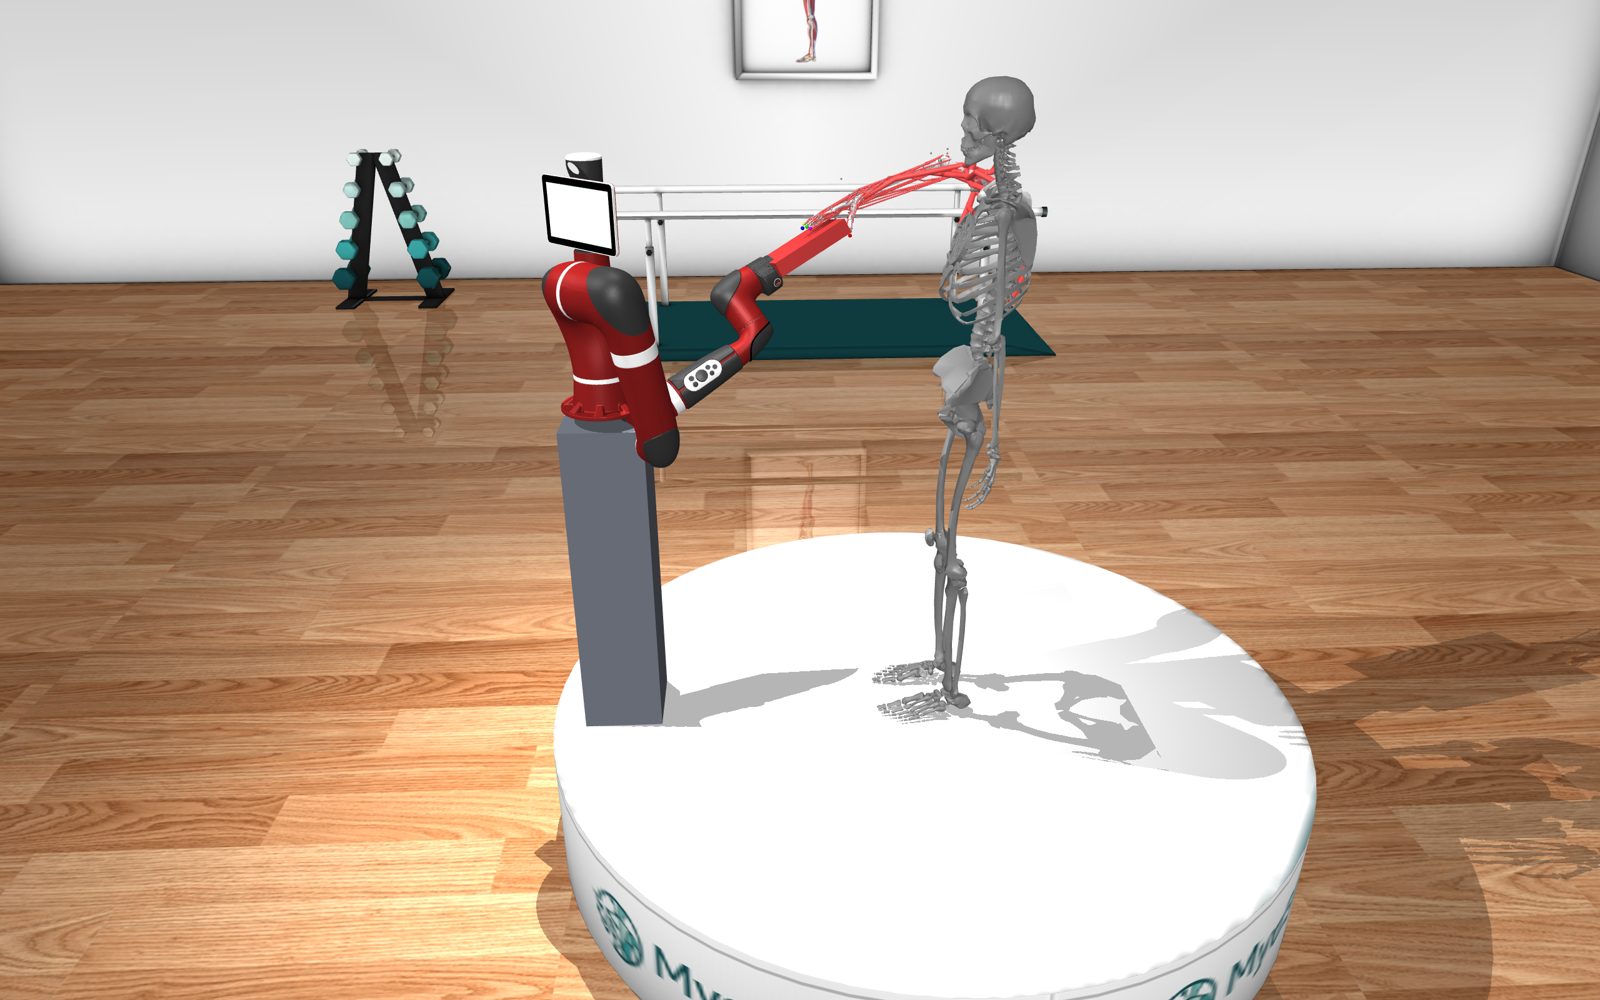
How should a cobot share a load with a person who has tremor? I tuned a Sawyer cobot under admittance–impedance control while coupled to a MyoSuite arm model.
Full-body Newton–Euler model of a quadruped, real-time MPC in MuJoCo, and reinforcement learning to correct dynamics the analytical model misses.
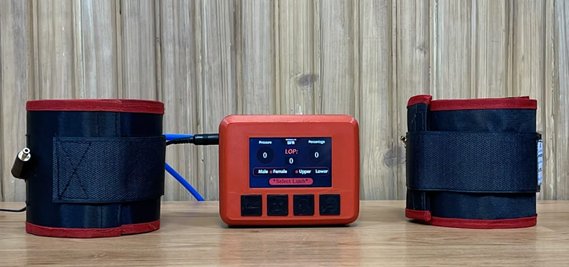
A working medical device prototype that sets cuff pressure from each user's measured limb occlusion pressure.
Industry, research and teaching.
What I bring to a control or robotics team.
Model Predictive Control, optimal control, admittance and impedance control, feedback design, MATLAB/Simulink
ROS 2, Nav2, MuJoCo, Gazebo, dynamic modeling, reinforcement learning for control
STM32, ESP32, analog circuits, signal processing; Python, C/C++, MATLAB
One book chapter, one accepted conference paper, one IEEE journal paper under review, two more under submission.
Two engineering degrees and three McGill awards.